Kontrol Sistemleri · Dijital ders notu
Control Systems – Lecture 1
- Ders
- Kontrol Sistemleri (ELEC322)
- Dönem
- 6. Dönem · 2023–2024 Bahar
- Biçim
- PDF · 3 sayfa · 0,1 MB · el yazısı görünümlü LaTeX
- Orijinal not
- Control-Systems-lecture-1.pdf
Uyarı: Dijital notlar, el yazısı notlardan Claude (Anthropic) yardımıyla oluşturulmuştur; yardımcı kaynak olarak hazırlanmıştır ve hata içerebilir. Orijinal notları ve resmi ders kaynaklarını esas alın.
The digital notes were created from the handwritten notes with the help of Claude (Anthropic); they are meant as a supplementary resource and may contain errors. Always rely on the original notes and the official course materials.
The digital notes were created from the handwritten notes with the help of Claude (Anthropic); they are meant as a supplementary resource and may contain errors. Always rely on the original notes and the official course materials.
Bu notta neler var?
- Control Systems
- Output should be
- Stability types
- Classification for control systems
Notun metni
Düz metin olarak göster (formüller ve çizimler yoktur)
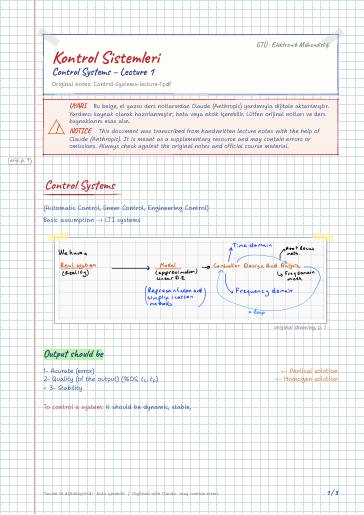
(Automatic Control, lineer Control, Engineering Control)
Basic assumption → LTI systems
Output should be
1- Acurate (error) Partical solution
2- Quality (of the output) (%OS, t_s , t_p ) Homogen solution
To control a system: it should be dynamic, stable,
Classification for control systems
SISO example : Regulators, Amplifiers, thermositor, dc motors, water controller in a pool,
MIMO Example: Autonom vehicle, Electrical distrubition system, aircraft systems, Internet Router, Camera, Temperature System of ( )
SIMO Example: Radar systems, Powerbank
MISO Example: A computer temp sytem with multiple sensors and one fan